Parking assistant
Take the distance reading and turn it into beep rate: slow far away, faster as you close in, solid at the stop point. Short to build, and it teaches you to turn a number into something a person can act on without looking at a screen. Averaging a few readings stops a single bad echo from making it stutter.
What this project uses
Every item is in the kit — nothing extra to buy.
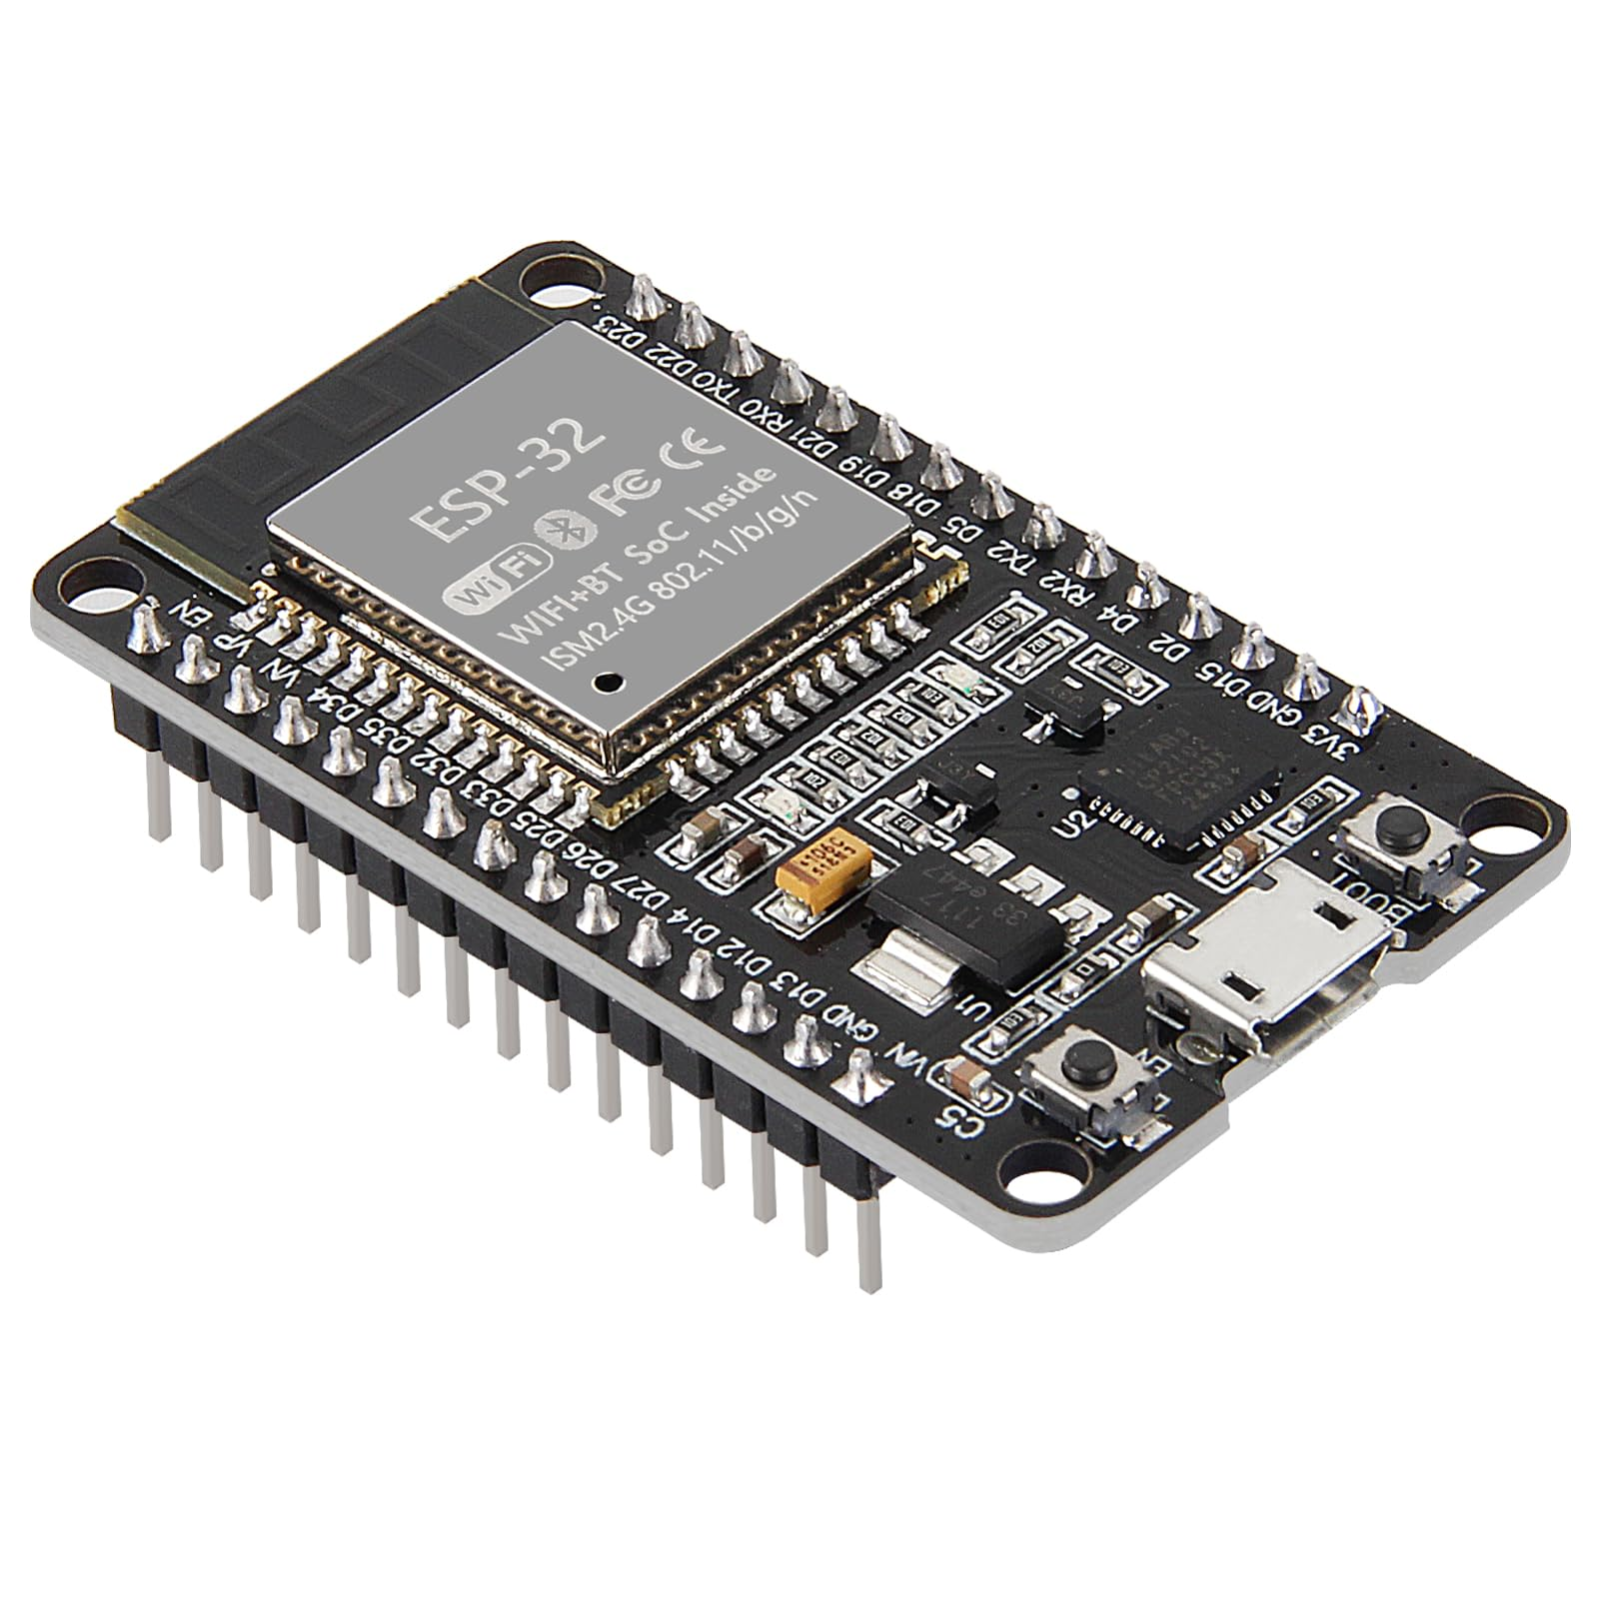



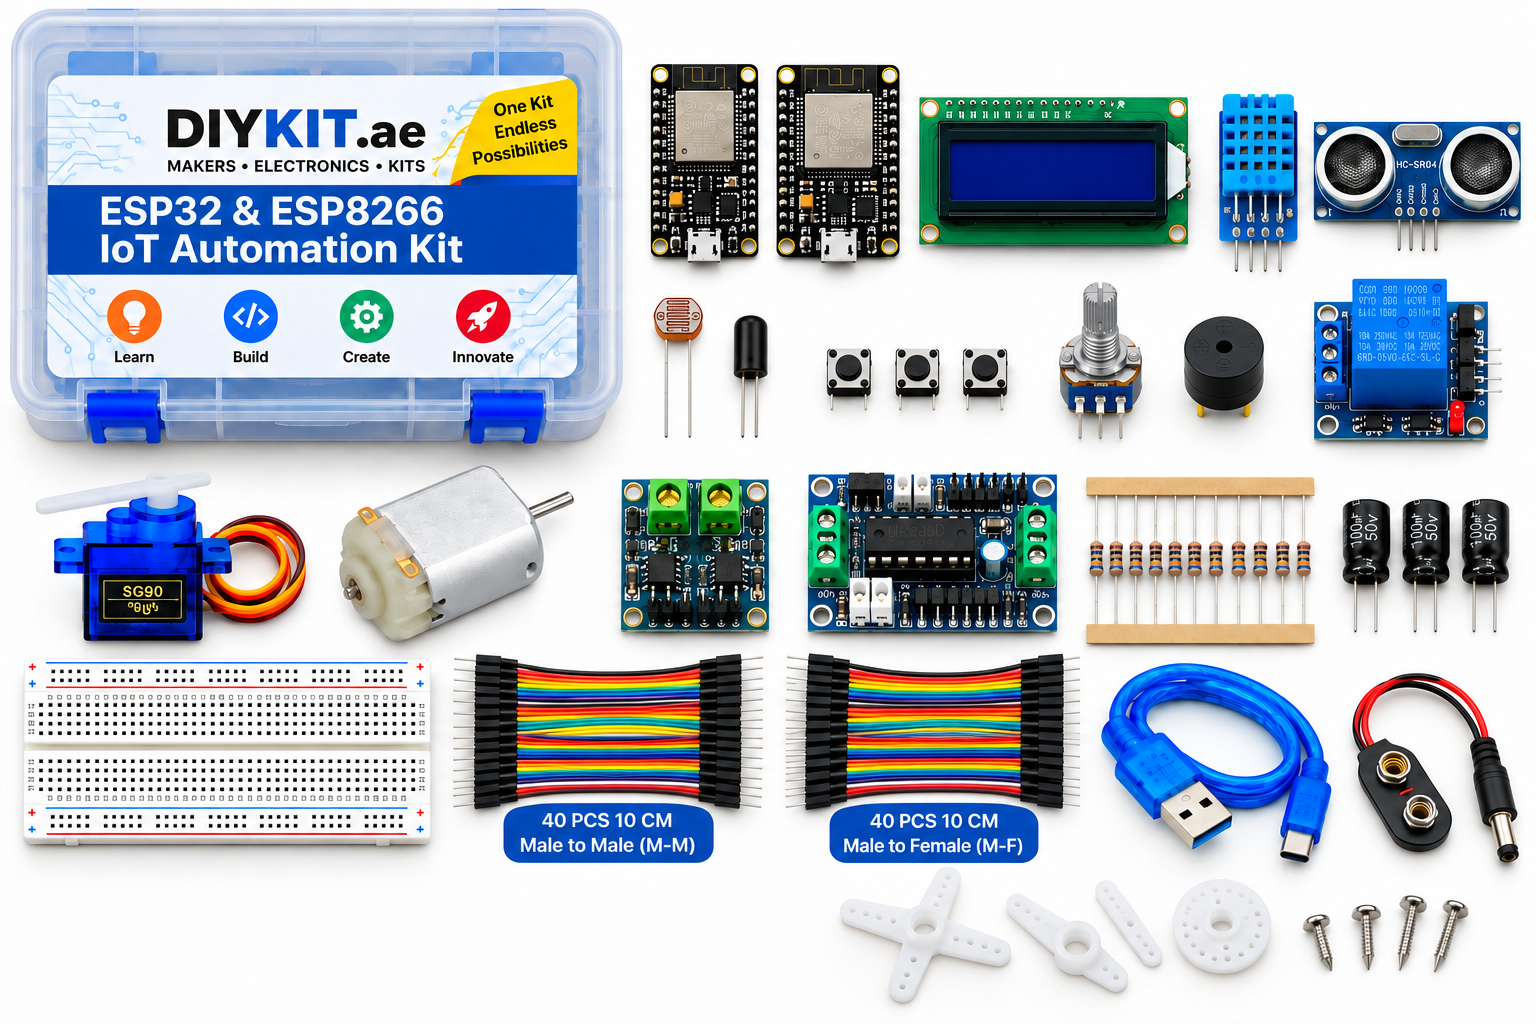
ESP32 & ESP8266 IoT Automation Kit
All 24 parts in one box, with this project and 15 more to build from them.
Need only these parts? Order them loose · from AED 104.05
One of each part. Packs (resistor assortment, jumper wires) already hold more than a single build needs. Backorder parts ship once they arrive — the kit above has every part boxed today. Delivery is free on orders AED 150.00+.
Sketch for this project
Written for the board in the kit. Copy it into the Arduino IDE; change the pin numbers if you wire it differently.
/*
  07 — Parking assistant
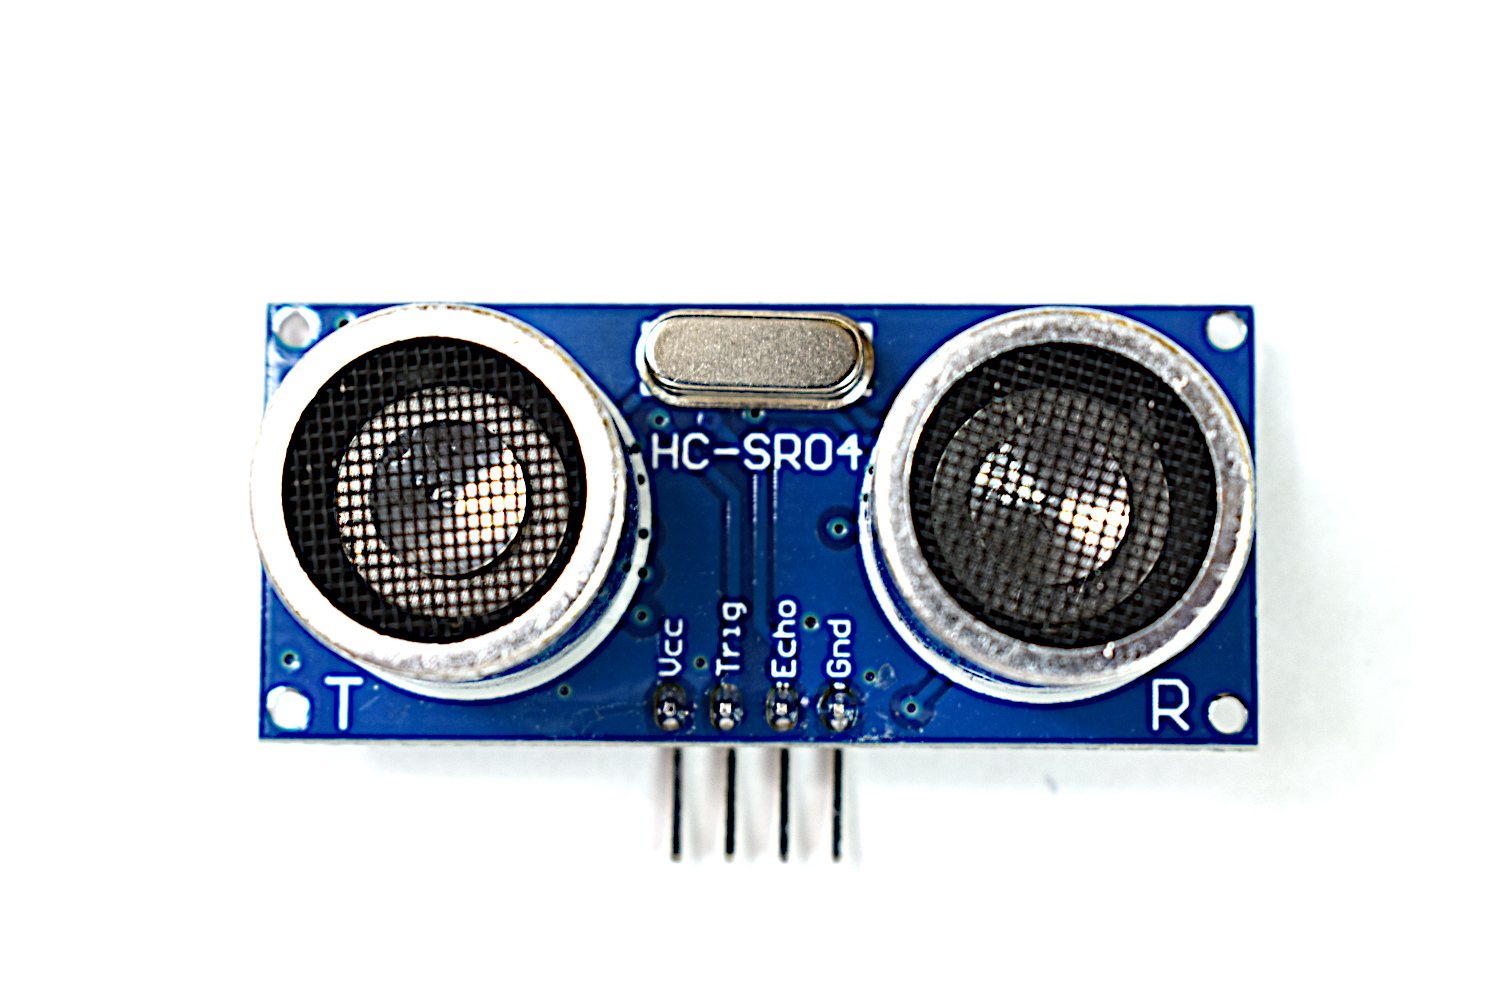
  Board: ESP32.  Parts: HC-SR04, buzzer module, 3 x 1 kΩ from the resistor pack.

  Wiring:
    HC-SR04: VCC -> VIN (5 V), GND -> GND, TRIG -> GPIO 5
             ECHO -> 1 kΩ -> GPIO 18, then two 1 kΩ in series from GPIO 18 -> GND
    Buzzer:  VCC -> 3V3, GND -> GND, IO -> GPIO 23   (active buzzer: HIGH = sound)

  Distance becomes beep rate: slow far away, faster closing in, solid at the
  stop line. Turning a number into something a person reacts to without a screen.
*/

const int TRIG_PIN   = 5;
const int ECHO_PIN   = 18;
const int BUZZER_PIN = 23;

const float STOP_CM  = 15;    // solid tone at or below this
const float FAR_CM   = 120;   // silent beyond this

float readCm() {
  digitalWrite(TRIG_PIN, LOW);  delayMicroseconds(2);
  digitalWrite(TRIG_PIN, HIGH); delayMicroseconds(10);
  digitalWrite(TRIG_PIN, LOW);
  unsigned long us = pulseIn(ECHO_PIN, HIGH, 30000UL);
  return us == 0 ? -1 : us / 58.0;
}

void setup() {
  Serial.begin(115200);
  pinMode(TRIG_PIN, OUTPUT);
  pinMode(ECHO_PIN, INPUT);
  pinMode(BUZZER_PIN, OUTPUT);
}

void loop() {
  // Average 3 readings — a single bad echo would make the beeps stutter.
  float sum = 0; int n = 0;
  for (int i = 0; i < 3; i++) { float d = readCm(); if (d > 0) { sum += d; n++; } delay(20); }
  float cm = n ? sum / n : -1;
  Serial.println(cm);

  if (cm < 0 || cm > FAR_CM) {            // nothing close: quiet
    digitalWrite(BUZZER_PIN, LOW);
    delay(100);
  } else if (cm <= STOP_CM) {             // stop line: solid
    digitalWrite(BUZZER_PIN, HIGH);
    delay(100);
  } else {                                // beep, faster as it gets closer
    int gap = map((int) cm, (int) STOP_CM, (int) FAR_CM, 60, 600);   // ms between beeps
    digitalWrite(BUZZER_PIN, HIGH); delay(40);
    digitalWrite(BUZZER_PIN, LOW);  delay(gap);
  }
}More from this kit
Read the room
The DHT11 sends both temperature and humidity down a single data wire using its own timing protocol, so a library does the decoding for you. Wire three pins, install the…
Temperature and humidity alarm
Show live readings on the LCD and sound the buzzer when the room crosses a threshold you set. The interesting part is what happens at the boundary: a naive version chatt…
Ultrasonic tape measure
Send a pulse, time the echo, divide by two, convert to centimetres. Unlike an analog sensor this is a timing measurement, so you meet pulse timing and microsecond resolu…