Lesson 5: Calibrate Your Sensor
Turn the UNO into a measuring instrument: type the ruler distance and it prints the average, error and spread of 10 readings, ready for a spreadsheet.
Before you start
Exact parts
| Part | How many |
|---|---|
| Wiring from Lesson 1 (the other parts can stay) | |
| Ruler or tape measure, flat card (yours) | 1 |
| Masking tape to mark distances (optional) |
Not in the box
- A ruler or tape measure and a flat piece of card (yours)
What you build and learn
- Calibration: comparing a sensor with something you trust
- Error and spread - two different ways a measurement can be wrong
- Sending a number from the computer to the UNO
- Copying data into a spreadsheet
You type the true distance from the ruler and press Enter. The sketch reads your digits one by one and builds the number: 2 then 0 makes 20.
It then takes 10 pings and prints one row: ruler_cm, average_cm, error_cm, min_cm, max_cm, spread_cm, echoes.
Error tells you whether the sensor reads too far or too near. Spread tells you how much it wobbles. A good sensor has both small.
Real sensors are often a little off in the same direction. Once you know the error, you could correct for it in code.
New words
- Calibrate
- Check a measuring tool against a known reference, such as a ruler.
- Error
- Reading minus true value. +2 means it reads 2 cm too far.
- Spread
- Biggest reading minus smallest. A small spread means steady readings.
- CSV
- Comma-separated values: rows of numbers with commas, which spreadsheets can read.
What this project uses
Every item below is in the kit. Not in the box: A ruler or tape measure and a flat piece of card (yours).

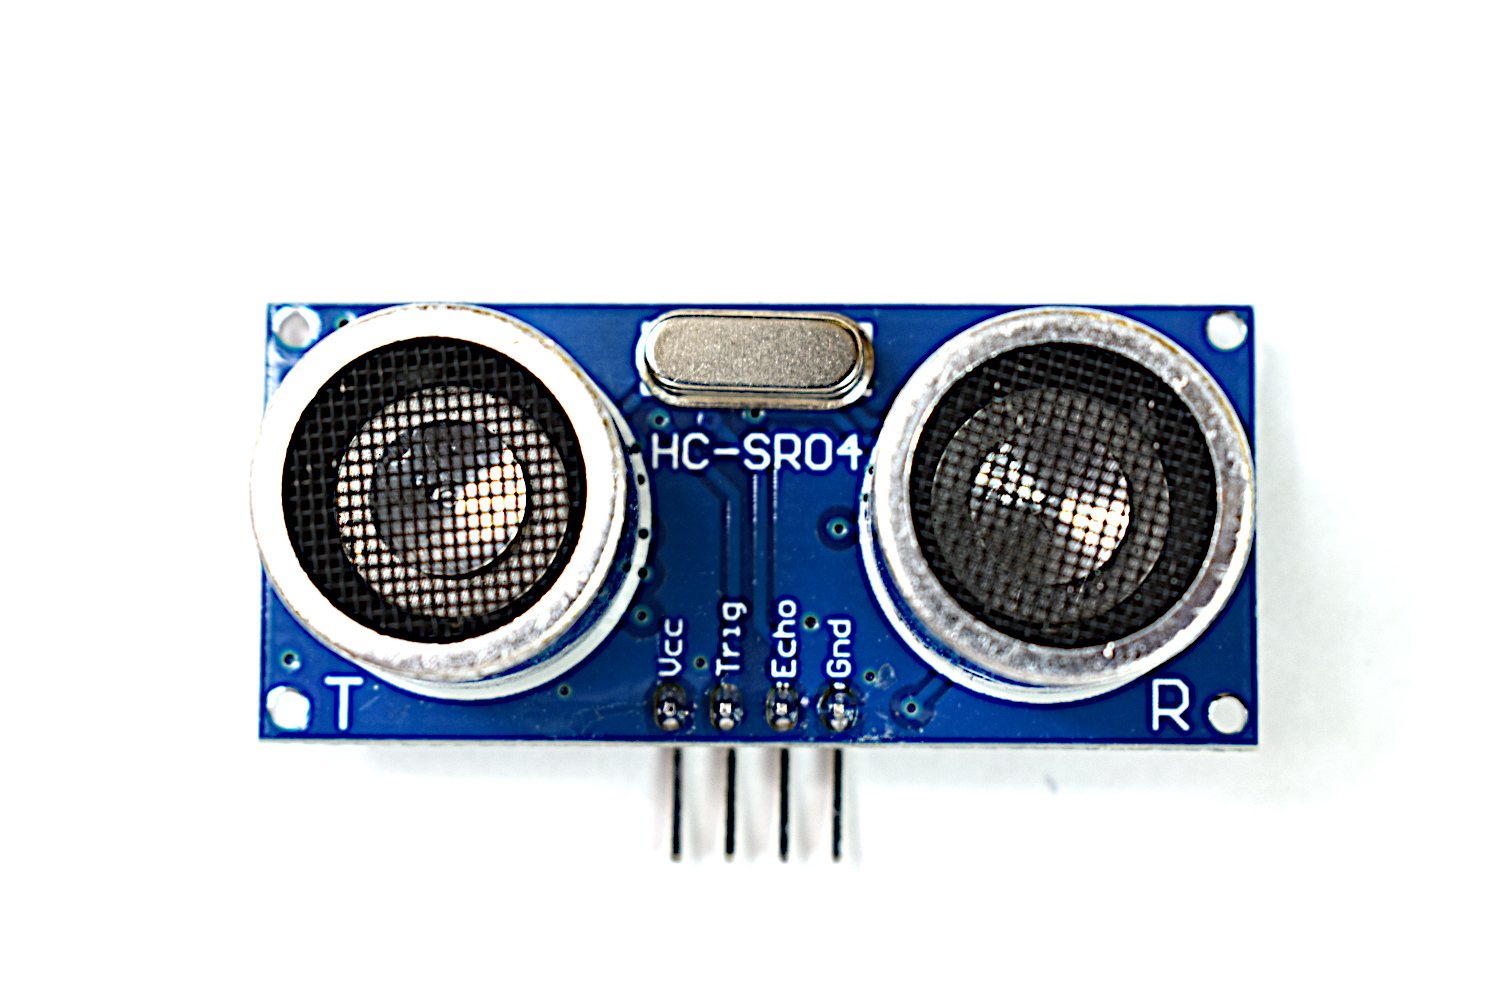
Arduino Ultrasonic Distance & Parking Learning Kit
All 9 parts in one box, with this project and 8 more to build from them.
Need only these parts? Order them loose · from AED 78.30
One of each part. Packs (resistor assortment, jumper wires) already hold more than a single build needs. a ruler or tape measure, a flat card, a spreadsheet (optional): included in the kit, ask us for it loose. Delivery is AED 20, free on orders AED 100+.
Connections
Unplug USB before you change any wire. Pin names are the labels printed on the board.
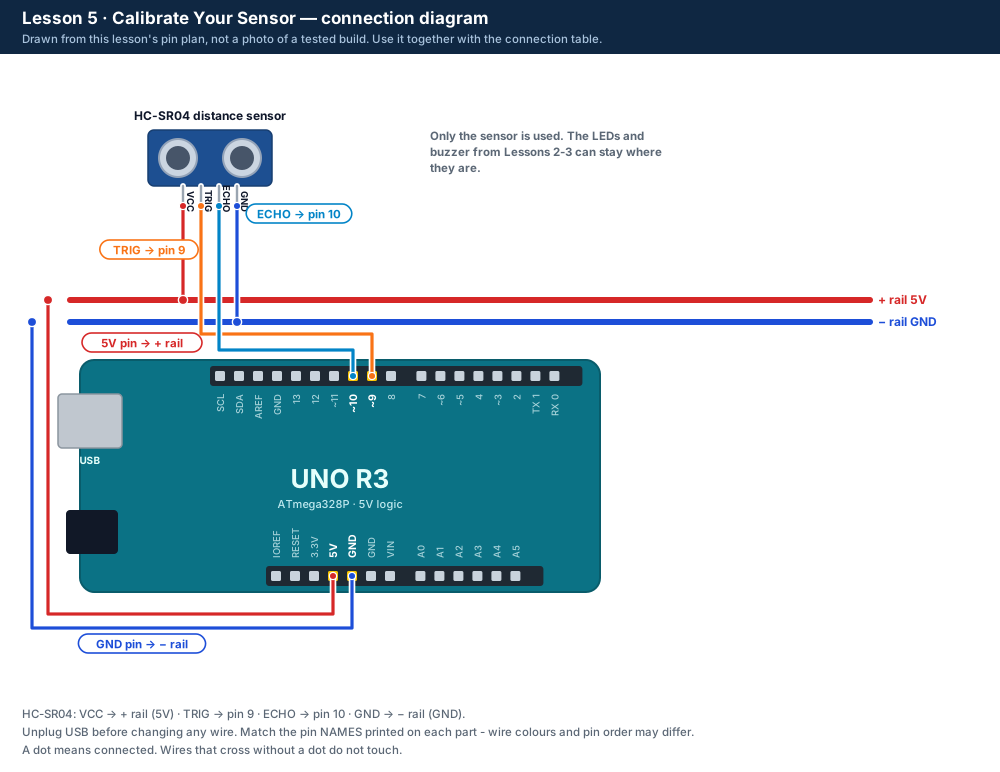
| Part / pin | Connect to | Note |
|---|---|---|
| No changes | Sensor as in Lesson 1 | TRIG pin 9 · ECHO pin 10 |
Step by step
One thing at a time. Tick nothing off until it matches the diagram.
- Upload the Lesson 5 code. No wiring changes are needed.
- Open the Serial Monitor at 9600 baud. In the box at the bottom right choose "New Line".
- Tape a ruler or tape measure to the table, starting at the front of the sensor's eyes.
- Stand the card upright and square to the sensor at 10 cm. Type 10 and press Enter. A row appears after about a second.
- Repeat at 20, 30, 50, 75 and 100 cm (as far as your table allows).
- Select the rows in the Serial Monitor, copy them, and paste them into a spreadsheet. Use Data → Split text to columns if they land in one column.
Sketch for this project
Written for the board in the kit. Copy it into the Arduino IDE; change the pin numbers if you wire it differently.
/*
  DIY KIT - Arduino Ultrasonic Distance & Parking Learning Kit
  Lesson 5 of 9: Calibrate Your Sensor

  WIRING: the sensor from Lesson 1 (TRIG pin 9, ECHO pin 10).
  The LEDs and buzzer can stay connected; this sketch does not use them.

  HOW TO USE IT
    1. Open the Serial Monitor at 9600 baud. Check the box at the bottom
       right is set to "New Line".
    2. Put a flat card at a ruler mark, for example 20 cm.
    3. Type 20 and press Enter. The UNO takes 10 readings and prints one row:
       ruler_cm, average_cm, error_cm, min_cm, max_cm, spread_cm, echoes
    4. Repeat at 10, 20, 30, 50, 75 and 100 cm. Copy the rows into a spreadsheet.
*/

const int TRIG_PIN = 9;
const int ECHO_PIN = 10;

const int SAMPLES = 10;                        // readings per row
const unsigned long ECHO_TIMEOUT_US = 30000;
const int MIN_CM = 2;
const int MAX_CM = 400;

long typedNumber = 0;     // the number being typed, digit by digit

long readOnceCm() {
  digitalWrite(TRIG_PIN, LOW);
  delayMicroseconds(2);
  digitalWrite(TRIG_PIN, HIGH);
  delayMicroseconds(10);
  digitalWrite(TRIG_PIN, LOW);
  unsigned long us = pulseIn(ECHO_PIN, HIGH, ECHO_TIMEOUT_US);
  if (us == 0) return 0;
  long cm = us / 58;
  if (cm < MIN_CM || cm > MAX_CM) return 0;
  return cm;
}

// Take SAMPLES readings and print one spreadsheet row.
void measureAt(long rulerCm) {
  long total = 0;
  long lowest = 9999;
  long highest = 0;
  int echoes = 0;

  for (int i = 0; i < SAMPLES; i++) {
    long cm = readOnceCm();
    if (cm > 0) {
      total = total + cm;
      echoes = echoes + 1;
      if (cm < lowest) lowest = cm;
      if (cm > highest) highest = cm;
    }
    delay(60);
  }

  Serial.print(rulerCm);
  Serial.print(",");
  if (echoes == 0) {
    Serial.println("NA,NA,NA,NA,NA,0");
    return;
  }
  long average = total / echoes;
  Serial.print(average);            Serial.print(",");
  Serial.print(average - rulerCm);  Serial.print(",");   // error: + means it reads too far
  Serial.print(lowest);             Serial.print(",");
  Serial.print(highest);            Serial.print(",");
  Serial.print(highest - lowest);   Serial.print(",");   // spread: how much it wobbles
  Serial.println(echoes);
}

void setup() {
  pinMode(TRIG_PIN, OUTPUT);
  pinMode(ECHO_PIN, INPUT);
  Serial.begin(9600);
  Serial.println("Lesson 5: Calibrate Your Sensor");
  Serial.println("Put the card at a ruler mark, type the distance in cm and press Enter.");
  Serial.println("ruler_cm,average_cm,error_cm,min_cm,max_cm,spread_cm,echoes");
}

void loop() {
  while (Serial.available() > 0) {
    char c = Serial.read();
    if (c >= '0' && c <= '9') {
      typedNumber = typedNumber * 10 + (c - '0');   // build the number one digit at a time
    } else if (c == '\n' || c == '\r') {
      if (typedNumber > 0) measureAt(typedNumber);
      typedNumber = 0;
    }
  }
  delay(1);
}Upload it
- Click Copy (or Download .ino and open the file).
- In the Arduino IDE choose File → New Sketch, select everything in it and paste.
- Check the bottom of the window says Arduino Uno and your port (Start here, step 5).
- Click Upload (the → arrow) and wait for Done uploading.
How the code works
| In the code | What it does |
|---|---|
| typedNumber = typedNumber * 10 + (c - '0'); | Builds the number from your digits: "2" then "0" → 2 → 20. |
| measureAt(rulerCm) | Takes 10 readings, keeps the smallest and biggest, and prints one CSV row. |
| average - rulerCm | The error: positive means the sensor reads too far. |
| highest - lowest | The spread: how much the 10 readings wobble. |
Change it and see
What you should see or hear
- At start: a title line, the instruction and the header ruler_cm,average_cm,...
- After typing 20 and Enter: one row like 20,21,1,21,22,1,10.
- Errors of 0-2 cm and spreads of 0-2 cm up close; bigger far away.
If it doesn't work
| Problem | What to check |
|---|---|
| Nothing happens when I press Enter | Choose "New Line" in the box at the bottom right of the Serial Monitor and try again. |
| The row says NA and 0 echoes | Nothing came back: square the card up to the sensor and check the wiring from Lesson 1. |
| All the rows land in one spreadsheet column | Use Data → Split text to columns (Google Sheets) or Data → Text to Columns (Excel) with comma. |
| Nothing or strange symbols in the Serial Monitor | Set the speed in the corner of the Serial Monitor to 9600 baud. Close the Serial Plotter if it is open. |
Small experiment
Make a chart of error against distance in your spreadsheet. Does the error grow as the card gets further away?
Check what you learned
The ruler says 50 cm and the average is 52. What is the error?
+2 cm: the sensor reads 2 cm too far.
Readings of 30, 31, 30, 33. What is the spread?
33 − 30 = 3 cm.
Why do we compare with a ruler?
Calibration needs a reference we trust more than the sensor.
Next
- Lesson 6 tests different targets and angles at one distance.
Stuck?
Most problems are one wire in the wrong hole. Check these first:
- Unplug, then compare every wire with the lesson's diagram and table. One pin off is the most common problem.
- Sensor: are VCC, TRIG, ECHO and GND wired by their labels, with TRIG on 9 and ECHO on 10?
- LEDs: is the long leg on the resistor side?
- Is the − rail connected to a UNO GND pin, and the + rail to 5V?
- Serial Monitor: is it set to 9600 baud (and "New Line" when you type commands)?
- Upload problems: is Tools → Board set to Arduino Uno and Tools → Port to your UNO? (Start here, step 5.)
Open the troubleshooting table for this step →
Hi DIY KIT, I'm stuck on the Arduino Ultrasonic Distance & Parking Learning Kit.
Lesson: __
Step number: __
What should happen: __
What happens instead: __
Error message (copied exactly): __
I'll attach a photo of my wiring.
More from this kit
Lesson 1: Measure Distance with Sound
Wire the HC-SR04 and read distances in the Serial Monitor. Compare them with a ruler to see how accurate the sensor really is. Do Start here first.
Lesson 4: Blind Zone & No Echo
Find the sensor's limits: too close, too far and off to the side. The LEDs and running counts show good readings, "too close" and "no echo".
Lesson 6: Angles & Surfaces
Why does the sensor sometimes miss things right in front of it? Fire 20 pings at flat, soft, round, thin and tilted targets and count how many echoes come back.
